Vulcan: Self-Driving Campus EV_
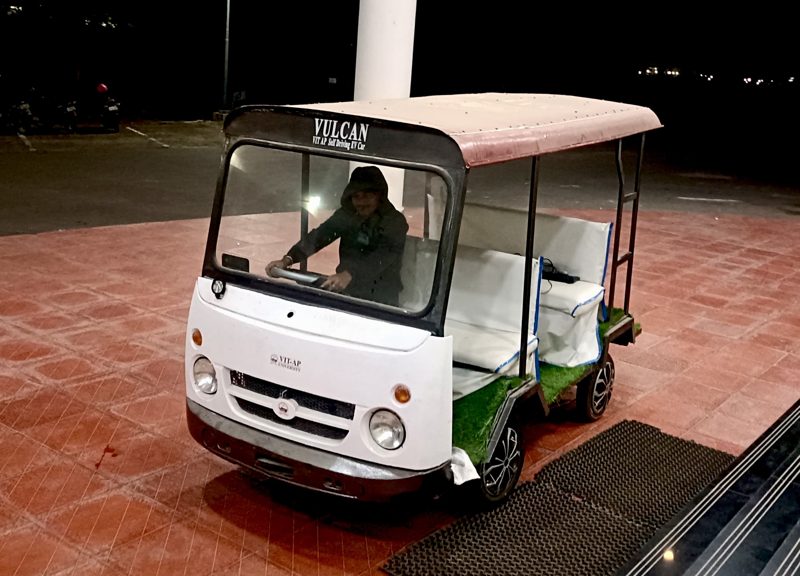
A self-driving electric campus vehicle and a VIT-AP initiative. I lead the student team building its perception, lane following and driving decisions. I trained DeepLabV3+ on Mapillary to 67% road-scene segmentation accuracy within the compute of an NVIDIA Jetson, built lane-following and turn-handling control, and trained driving policies in CARLA with SAC, refined with DAgger. The working vehicle was showcased live at VLaunchpad 2025.
Built with
ROS · CARLA · DeepLabV3+ · SAC · DAgger · NVIDIA Jetson